
Publication archive
Robotic ALG handling
Insight into a published application or lecture from the CRETEC archive.
Archive content: Information refers to the original publication status. Please coordinate current execution, scope of services and availability with CRETEC.
Robotic ALG handling
Project type:
Automotive
Date
2023
Request
The existing End of Line Station is to be further automated.
Status at the moment is that there are two employees working in a three-shift operation around the ALG from
line, provided with stoppers and inserted into the transport box.
Process at the moment:
- MA 1 sets several stoppers
- MA 1 sticks label with internal ID to the loader
- ID system reads label and unlocked device
- MA 1 removes loaders by crane
- MA 1 hands over crane to MA 2
- MA 2 reads ID by hand scanner
- MA 2 sets stopper
- MA 2 checks manually optically for different features
- MA 2 puts loader in shipping box
- Vision System reads nameplate and controls the seat of each stopper
Power connectors
Objective Process:
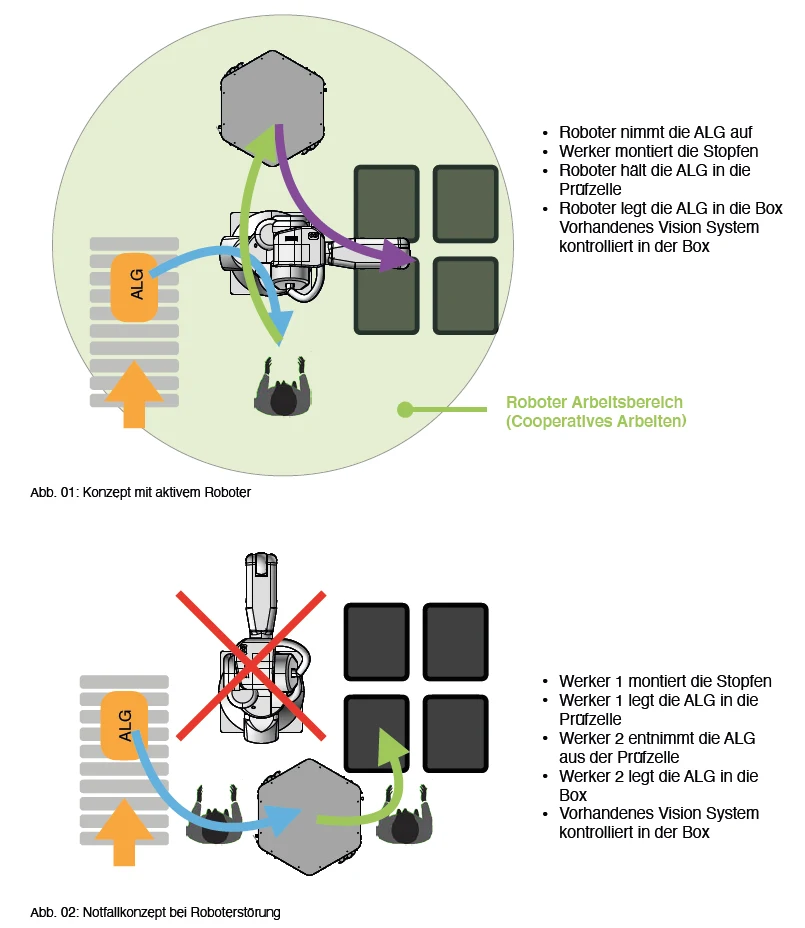
- The label is applied by the employee to the loader
- The ID system reads the code on the label and starts the process.
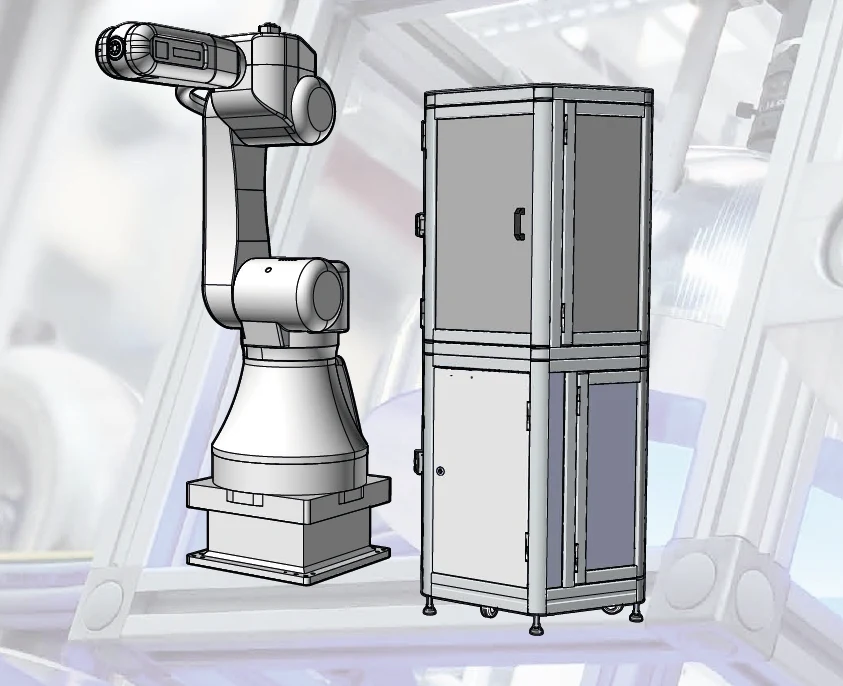
- The robot removes the loader and presents it to the MA so that the plugs are placed
may be:
- The MA sets the stoppers
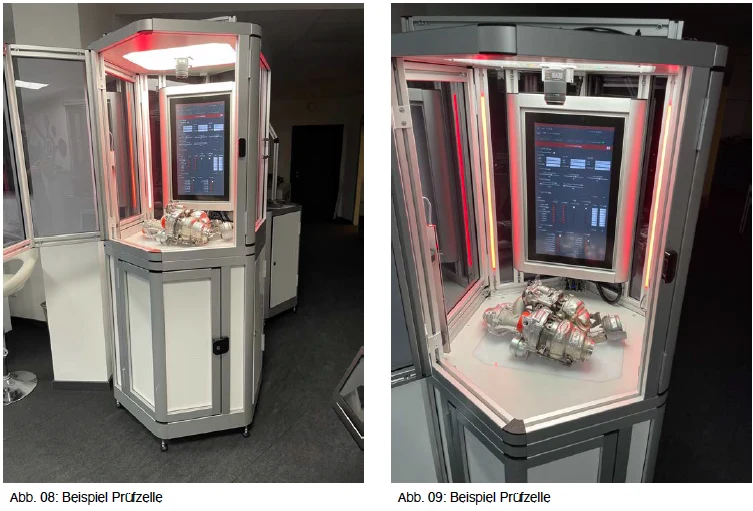
- The robot holds the loader in the inspection cell
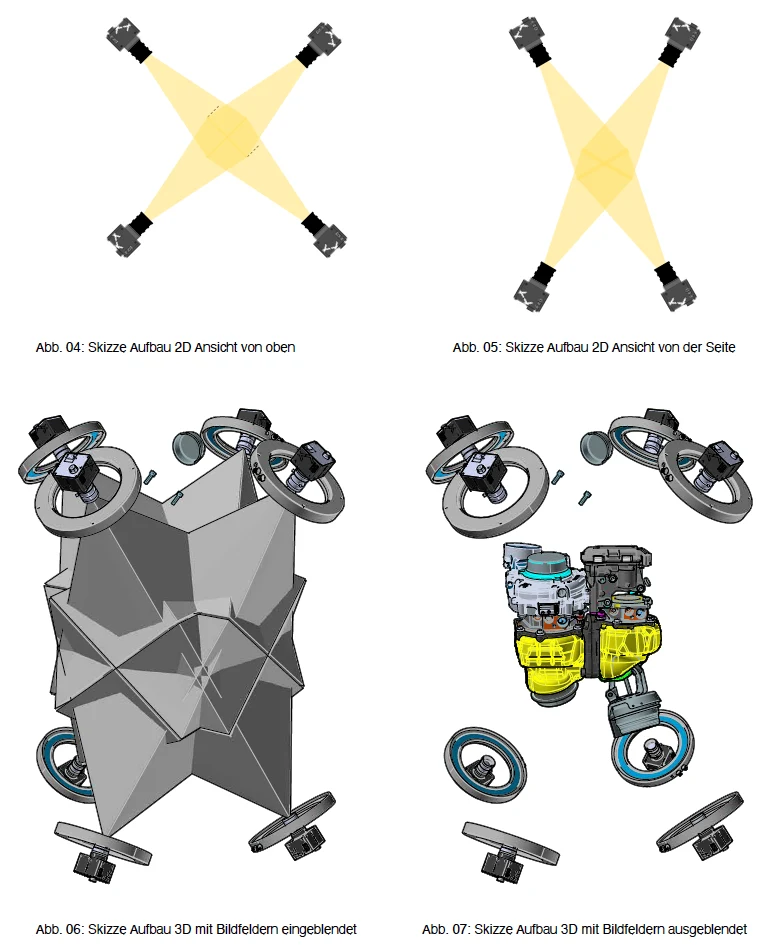
- There all the details are checked
- The robot puts the loader in the box
- The existing VisionaryVision system continues to document the completeness in the box
The required development for this is carried out jointly by the customer and Cretec
Cretec designs the required hardware, manufactures it and delivers it to the customer
- Inspection cell with cameras and lighting. computer, etc.
- Robots
- Project-specific gripper
- The customer programs the robot and the test scripts
- CRETEC and the customer jointly put the applications into operation
Request for this application →