
Publication archive
Moving-object detection: X/Y/rotation
Insight into a published application or lecture from the CRETEC archive.
Archive content: Information refers to the original publication status. Please coordinate current execution, scope of services and availability with CRETEC.
Moving-object detection: X/Y/rotation
Project type:
Automation
Date
2019
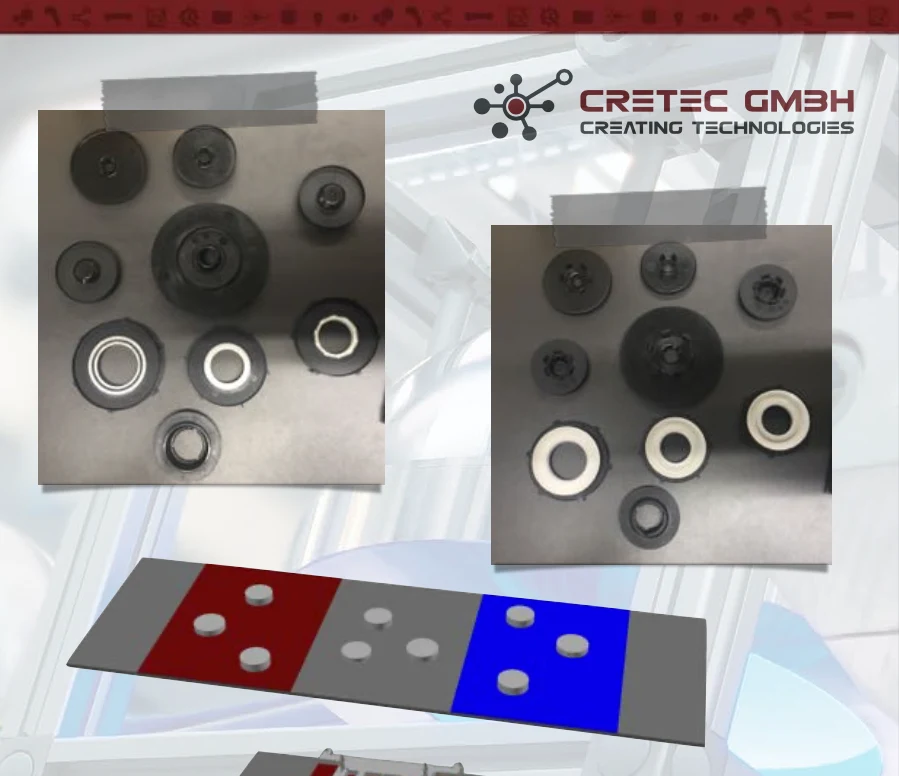
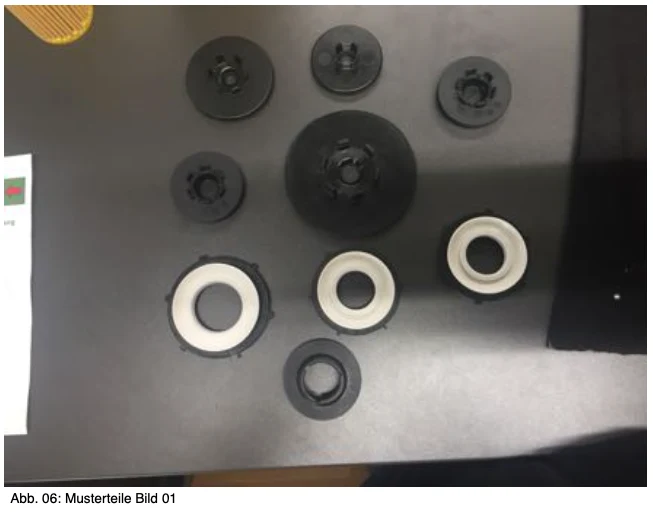
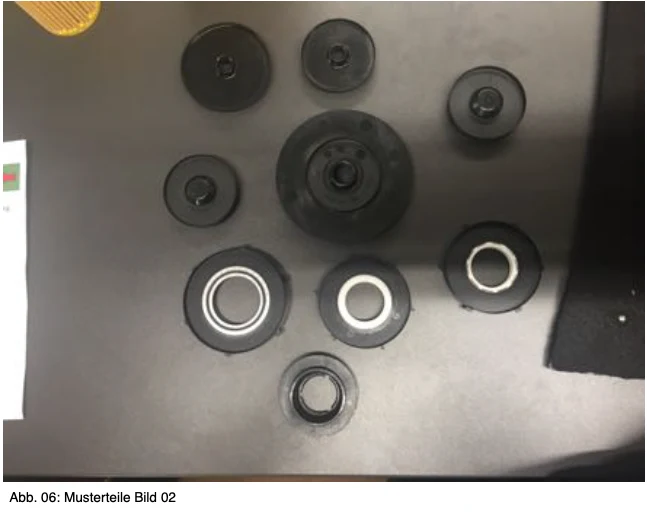
The customer creates a new system, which is to take part under inspections off the assembly line during the journey. Parts under inspection are separated and drop onto a belt. From this belt, a robot picks up the parts during travel and places them in a centering station. The parts under inspection are purified by sorting.
In order to make this possible, a camera system is required which detects the X/Y/R as well as the Z positions of the parts under inspection on the tape set for the type and transmits them to the robot. At the same time, the camera system must detect whether the part under inspection is lying on the head or on the feet. The required accuracy that the robot can grip the part under inspection is approx. 1,5 mm.
The field of view where the parts under inspection must be recognized is approximately 400 mm (bandwidth) * 300 mm. There is a triggering every second.
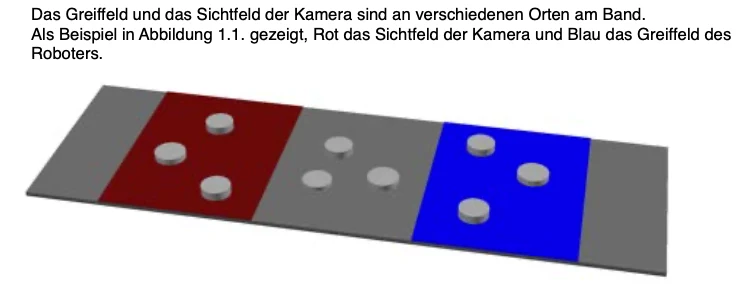
The gripping field and the field of view of the camera are in different places on the tape.
Request for this application →